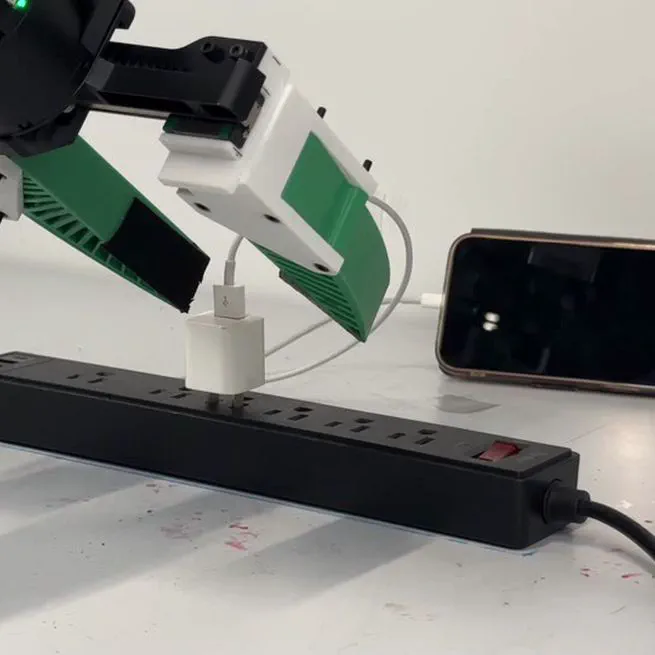
Robot Learning with Visual Predicted Force
Force-aware manipulation without force or tactile sensors, using force predicted visually from a compliant Fin Ray gripper to guide action selection.
Oct 3, 2026
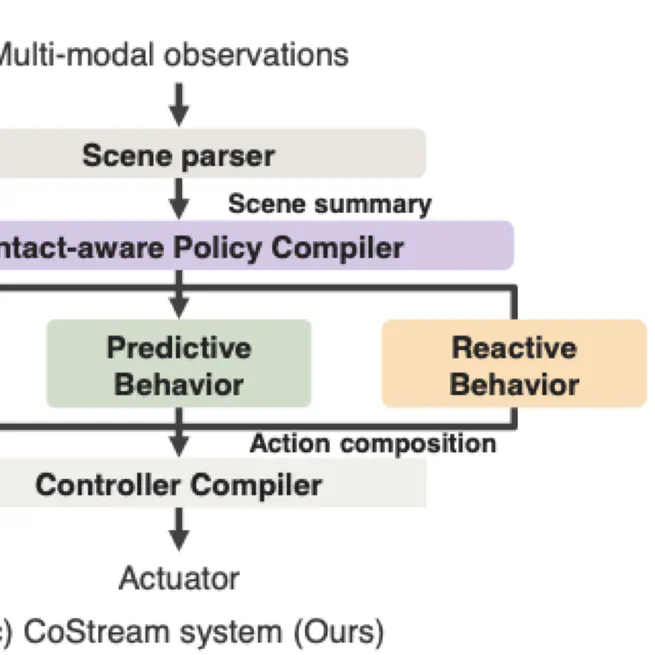
CoStream: Composing Simple Behaviors for Generalizable Complex Manipulation
Composing semantic, predictive and reactive behaviors on a shared SE(3) interface, so that long-horizon precision manipulation emerges without per-task retraining.
Jun 1, 2026