Robot Learning with Visual Predicted Force
Oct 3, 2026·,,,,,,,,,,,,,·
0 min read
Haonan Chen
Feiyang Wu
Yuxiang Ma
Mustafa Mete
Pengfei Ye
Junxuan Shen
Cheng Zhu
Aurora Ruggeri
Kelvin Cheung
Jiayuan Mao
Edward Adelson
Jiajun Wu
Robert D. Howe
Yilun Du
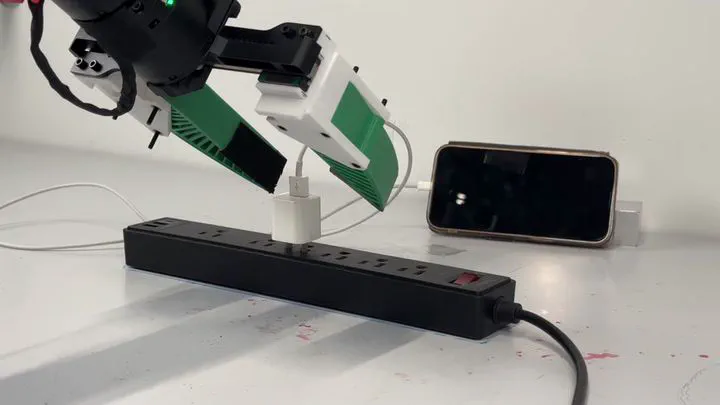 Contact-rich insertion guided by visually predicted force.
Abstract
Force-aware manipulation typically relies on specialized force or tactile sensors. We show that force-aware manipulation can instead be achieved through visual force prediction from the deformation of a compliant Fin Ray gripper. Our approach trains two models. First, we train a visual force estimator on calibration data and use it to annotate task demonstrations with force estimates. Second, we train an action–force proposal policy on these force-augmented demonstrations to jointly generate candidate robot actions and their associated forces. At test time, we sample candidate actions and the forces they are expected to produce, then execute the action whose predicted force is closest to a target from the demonstrations. We evaluate our approach on berry picking, empty-can grasping, in-hand reorientation, and plug insertion. Our results show that visual force prediction can guide inference-time action selection for contact-rich manipulation without requiring force or tactile sensors at deployment.
Type
Publication
Under review, ICRA 2027